Brain-inspired embodied intelligence
Weiyu Guo 郭伟钰
Head of Embodied Foundation Models
Principal Investigator (PI), XLab
AI² Robotics 智平方Leading company-wide embodied foundation model development and frontier embodied AI research.
I build models that connect perception, memory, and control. My research brings insights from the brain into embodied AI, for robots that understand the world and act within it.
Research
Perception, memory, and control in the physical world.
Built in the open
StarVLA
Co-founder & core developerA modular, Lego-like codebase for VLA development, from model backbones and action heads to training and evaluation.
AlphaBrain
Brain-inspired embodied AI platformA platform for exploring brain-inspired control, with NeuroVLA documentation and a practical reproduction entry point.
Research perspective
沿着生物进化的神奇蓝图,推动物理智能前进。
Guided by evolution’s remarkable blueprint, advancing physical intelligence.
Human-like sensing
Neural interfaces, surface electromyography, and event-driven vision for robust perception.
sEMG / Event cameras / Neural decodingBrain-inspired architecture
Spiking neural networks and hierarchical neural architectures that link understanding with real-time control.
SNNs / Neuromorphic computing / HierarchyAction-grounded learning
Vision-Language-Action models, spatial memory, continual skill learning, and humanoid robotic control.
VLA / World models / Robot manipulationLatest updates
Updated SL-FM preprint on intervenable multimodal imitation.
DeltaWAM: incremental visual memory for bimanual manipulation.
Joined MMLab, CUHK as a Postdoctoral Fellow.
Earlier updates
- 2026.08: Postdoctoral Fellow at MMLab, CUHK.
- 2026.08: Our StarVLA reaches 3.5K+ stars on GitHub!
- 2026.08: New preprint: How Should Vision-Language-Action Models Use Proprioceptive State? is out on arXiv!
- 2026.07: New preprint: The Geometry of Flow-Matching Uncertainty is out on arXiv!
- 2026.05: Released our AlphaBrain Platform!
- 2026.05: One paper accepted at ICML 2026!
- 2026.04: Our StarVLA report has been published!
- 2026.02: Our StarVLA reaches 2.6K+ stars on GitHub!
- 2025.12: StarVLA selected as one of the Top 10 Most Influential Open-Source Embodied AI Repositories!
- 2025.10: One paper accepted at AAAI 2025!
- 2025.09: One paper accepted at IJCV 2025! Two papers accepted at NeurIPS 2025!
- 2025.01: One paper accepted at ICLR 2025!
- 2024.09: One paper accepted at NeurIPS 2024!
- 2024.07: One paper accepted at CVPR 2024!
XLab
AI² Robotics ↗让智能扎根真实世界,
拓展人类能力的边界。
Ground intelligence in the real world.
Expand the horizons of human capability.
As Principal Investigator of XLab at AI² Robotics (智平方), I oversee embodied foundation models and frontier embodied AI research. Our mission is to build general-purpose embodied intelligence that learns through interaction, understands the physical world, and acts with autonomy, extending human capability through robotics.
Memory & learning
Spatial memory beyond the camera view, phase-aware experience replay, and efficient world-action modeling.
Perception & reliability
Event-driven sensing, proprioceptive state design, and lightweight failure detection for closed-loop manipulation.
Controllable action
Intervenable action generation, auditing capability edits, and robotic failure analysis for scientific laboratories.
XLab Research Showcase
Selected joint-laboratory and team research
Tactile learning
TACO ↗
Tactile world models for self-correction and robot policy post-training.
Team work · Preprint 2026
World models
Video2Act ↗
A dual-system video diffusion policy for spatial and motion modeling.
Team work · Preprint 2025
Digital-twin learning
Twin-DAgger ↗
Failure-aware digital-twin augmentation guided by human corrections for efficient robot manipulation.
Team work · ECCV · 2026
Humanoid motion
MotionVLA ↗
Language-driven motion with separate base structure and physical detail.
Team work · Preprint 2026More team research directions
Digital-twin learningTargeted interactive corrections for more efficient imitation learning.
DeTacDecoupling illumination and deformation in tactile imaging.
TriPerActive multi-view perception for occluded objects.
Dynamic graspingHigh-speed spike vision with persistent pose tracking.
Research directions from our August 2026 team overview.
Selected publications
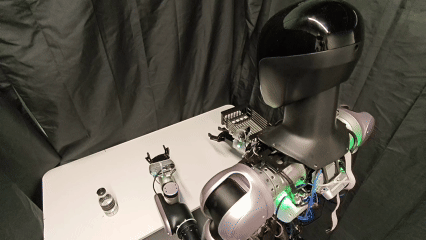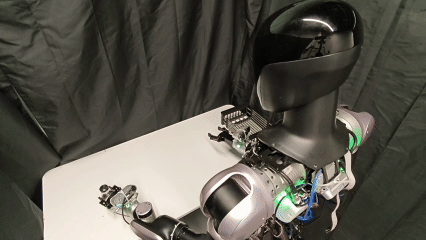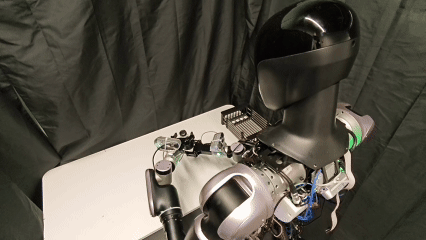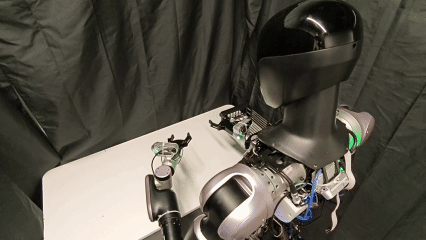
Google Scholar ↗A Brain-inspired Embodied Intelligence for Fluid and Fast Reflexive Robotics Control
A cortex-cerebellum-spinal cord hierarchy for semantic planning, smooth motion, and fast local feedback.
Project Leader
Spatial Memory for Out-of-Vision Manipulation in Vision-Language-Action.
Persistent spatial-semantic memory for manipulating objects beyond the current field of view.
Corresponding Author Project Leader
PHASER: Phase-Aware and Semantic Experience Replay for Vision-Language-Action Models
Phase-aware memory replay to preserve brief but critical subskills during continual learning.
Project Leader
DeltaWAM: Delta World Action Models for Bimanual Manipulation
Streaming Delta Memory reuses visual context and models sparse changes for efficient bimanual manipulation.
Corresponding Author Project Leader
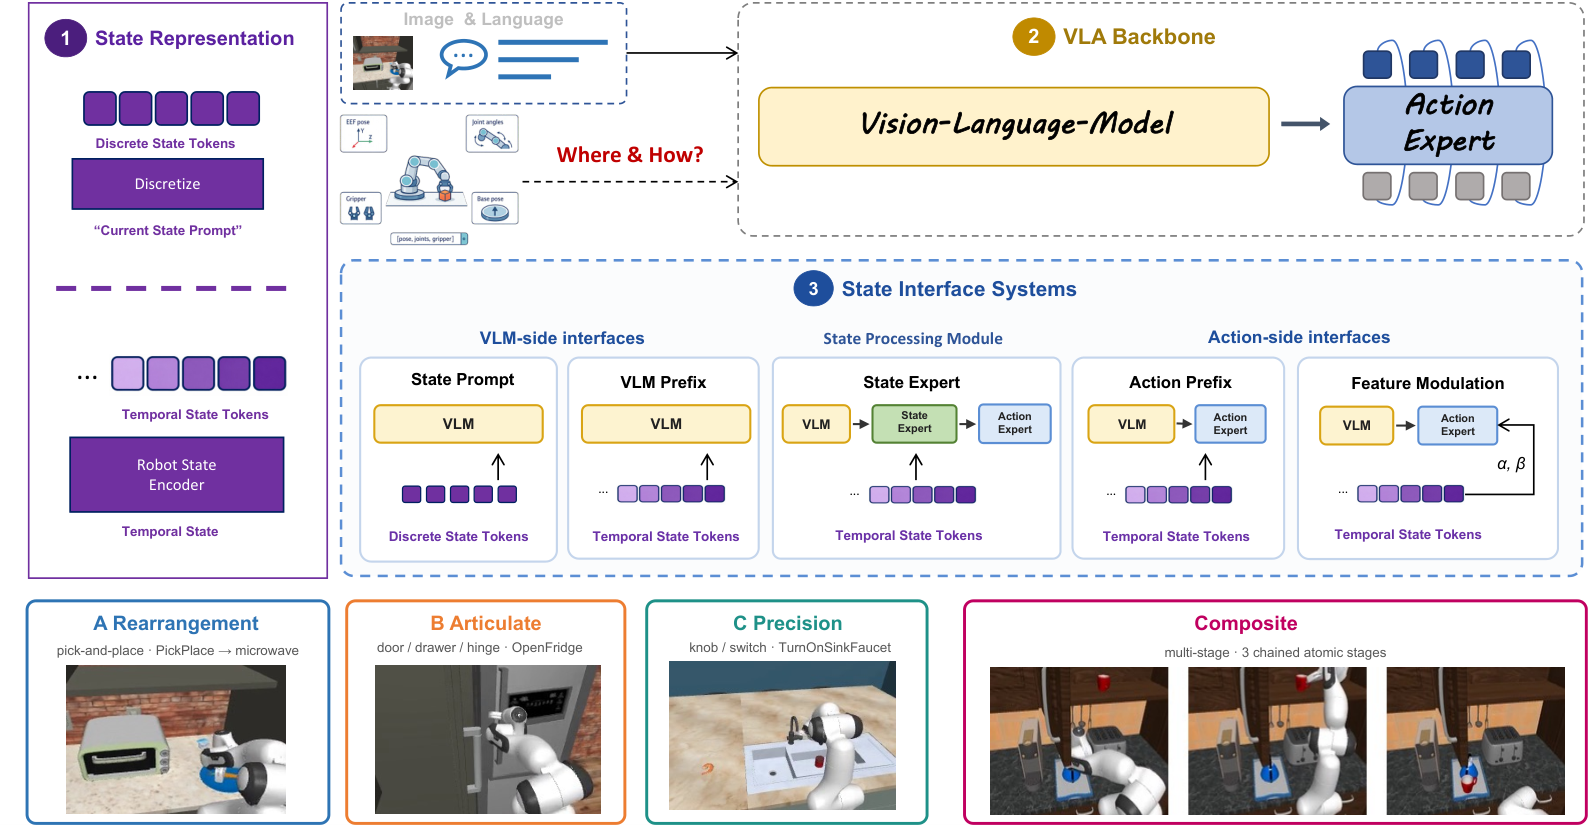
How Should Vision-Language-Action Models Use Proprioceptive State?
A systematic study of where and how robot state and its temporal history should enter a VLA model.
Project Leader
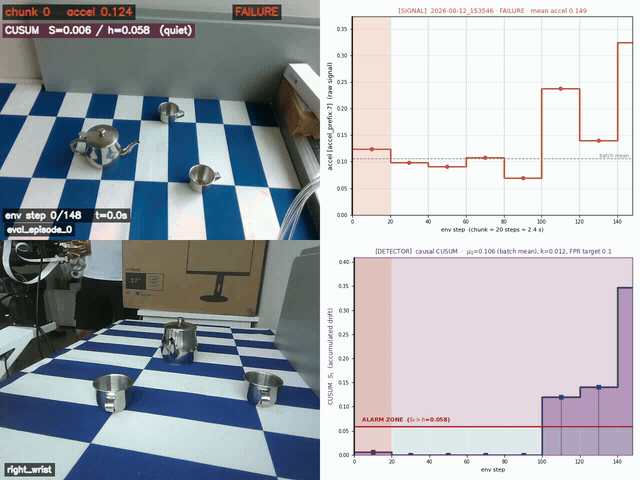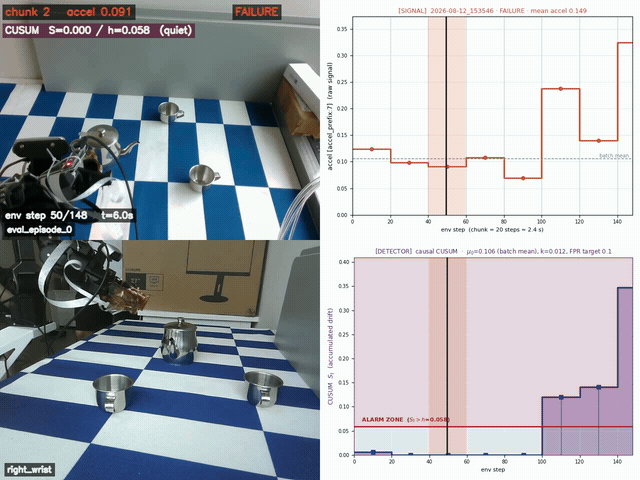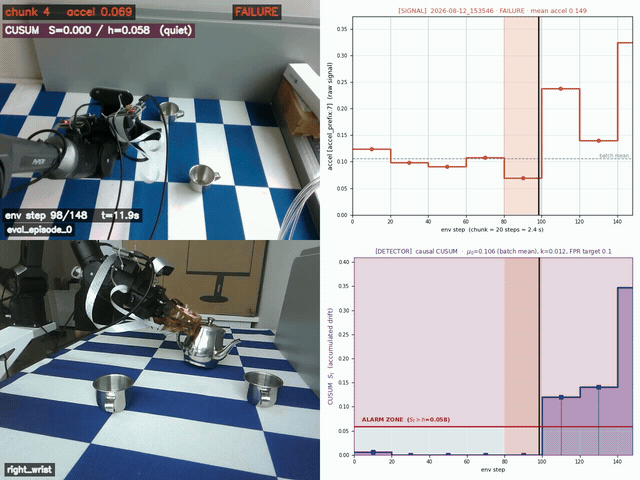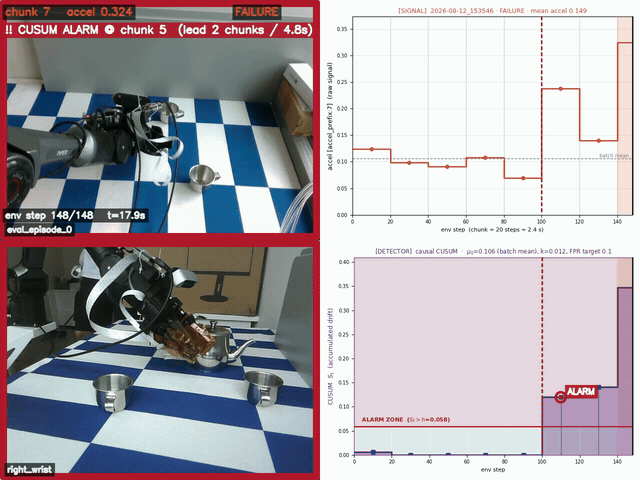
The Geometry of Flow-Matching Uncertainty: A Cost-free Uncertainty Proxy and Its Application in Flow-based VLA Failure Detection.
Failure-risk signals from the geometry of an existing flow-matching inference trajectory, without extra model evaluations.
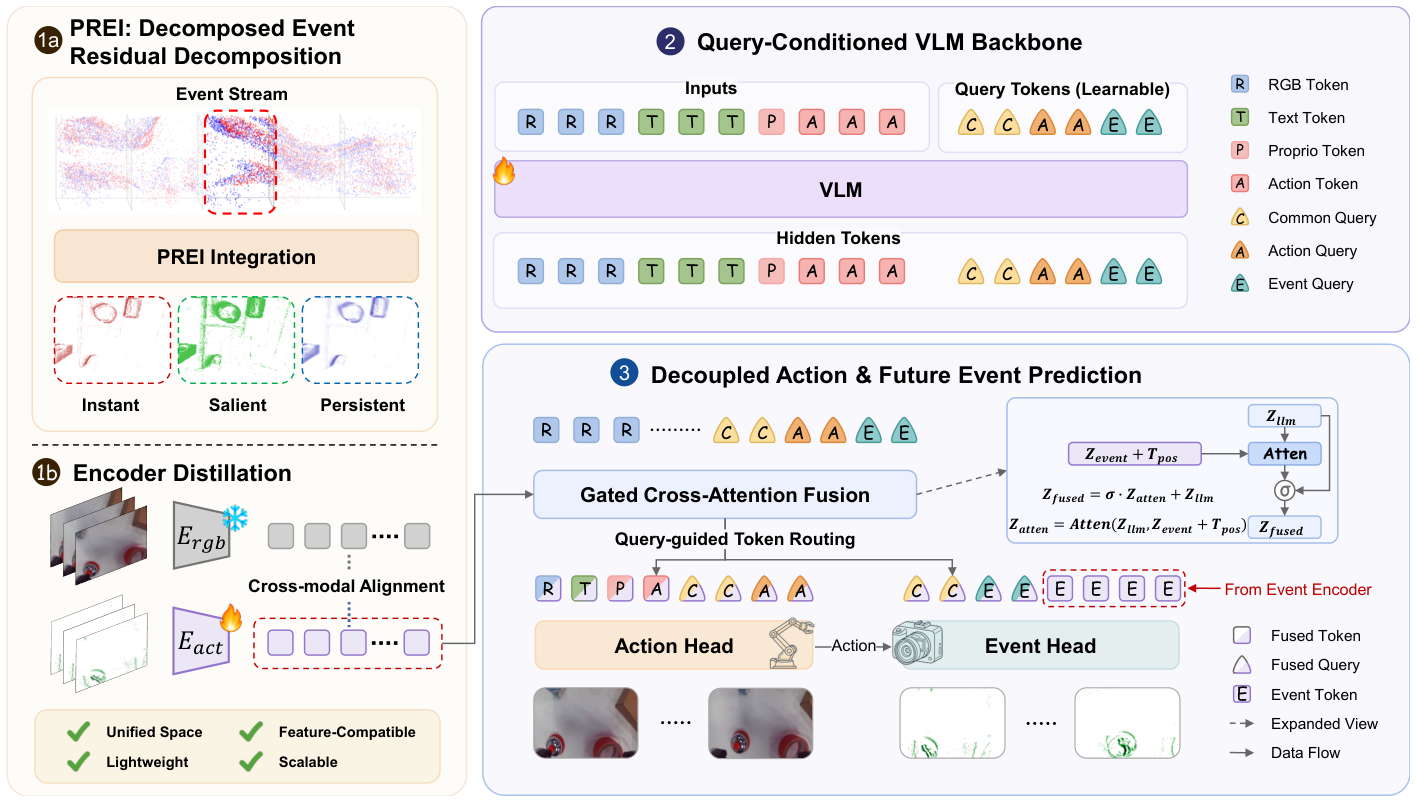
Event-VLA: Action-Conditioned Event Fusion for Robust Vision-Language-Action Model
Action-conditioned fusion of RGB semantics and event-camera motion cues for robust low-light manipulation.

Logic-in-Frames: Dynamic Keyframe Search via Visual Semantic-Logical Verification for Long Video Understanding.
Dynamic keyframe search guided by visual semantic and logical verification for long videos.

Revisiting Noise Resilience Strategies in Gesture Recognition: Short-Term Enhancement in sEMG Analysis
Short-term enhancement for noise-resilient surface electromyographic gesture recognition.

SpGesture: Source-Free Domain-adaptive sEMG-based Gesture Recognition with Jaccard Attentive Spiking Neural Network.
Source-free adaptation with attentive spiking neural networks for sEMG gesture recognition.

Context-Enhanced Stereo Transformer.
Context-aware transformer representations for stereo correspondence.

Long exposure convolutional memory network for accurate estimation of finger kinematics from surface electromyographic signals.
Continuous finger-kinematics estimation from surface electromyographic signals.

Multi-attention feature fusion network for accurate estimation of finger kinematics from surface electromyographic signals.
Feature fusion for continuous finger-kinematics estimation.
Additional publications & selected patents
Other publications
-
Li, Pengteng, Song, Pinhao, Li, Wuyang,
Guo, Weiyu, Yao, Huizai, Xu, Yijie, Liu, Dugang, Xiong, Hui. “See&Trek: Training-Free Spatial Prompting for Multimodal Large Language Model.” NeurIPS (2025) Paper -
Yao, Huizai, Zhao, Sicheng, Li, Pengteng, Cui, Yi, Lu, Shuo,
Guo, Weiyu, Lu, Yunfan, Xu, Yijie, Xiong, Hui. “Beyond Boundaries: Leveraging Vision Foundation Models for Source-Free Object Detection.” AAAI (2026) -
Wang, Shaoguang,
Guo, Weiyu, Chen, Ziyang, Xu, Yijie, Hu, Xuming, Xiong, Hui. “Less is More: Token-Efficient Video-QA via Adaptive Frame-Pruning and Semantic Graph Integration.” CVPR Findings (2026) -
He, Jianxiang, Hong, Meisheng, Li, Jungang,
Guo, Weiyu, Hu, Xuming, Xiong, Hui. “VSI: Visual Subtitle Integration for Keyframe Selection to Enhance Long Video Understanding.” CVPR Findings (2026) -
Li, Pengteng, Lu, Yunfan, Song, Pinhao,
Guo, Weiyu, Yao, Huizai, Yu, F. Richard, Xiong, Hui. “DeblurSplat: SfM-free 3D Gaussian Splatting with Event Camera for Robust Deblurring.” IEEE TMM (2026). IEEE Paper -
Sun, Guoying,
Guo, Weiyu, Shao, Tong, Yang, Yang, Zeng, Haijin, Liu, Jie, Su, Jingyong. “BrainCognizer: Brain Decoding with Human Visual Cognition Simulation for fMRI-to-Image Reconstruction.” IEEE BIBM (2025). IEEE -
Lu, Yunfan, Xu, Yijie, Ma, Wenzong,
Guo, Weiyu, Xiong, Hui. “Event camera demosaicing via swin transformer and pixel-focus loss.” CVPR (2024) -
Guo, Weiyu, Sun, Guoying, He, JianXiang, Shao, Tong, Wang, Shaoguang, Chen, Ziyang, Hong, Meisheng, Sun, Ying, Xiong, Hui. “A Survey of fMRI to Image Reconstruction.” arXiv preprint arXiv:2502.16861 (2025) Paper -
Lu, Yunfan, Xu, Xiaogang, Lu, Hao, Qian, Yanlin, Li, Pengteng, Yao, Huizai, Yang, Bin, Li, Junyi, Cai, Qianyi,
Guo, Weiyu. “SEE: See Everything Every Time–Adaptive Brightness Adjustment for Broad Light Range Images via Events.” arXiv preprint arXiv:2502.21120 (2025) Paper -
Lin, Chuang, Zhao, Chunxiao, Zhang, Jianhua, Chen, Chen, Jiang, Ning, Farina, Dario,
Guo, Weiyu. “Continuous Estimation of Hand Kinematics from Electromyographic Signals based on Power-and Time-Efficient Transformer Deep Learning Network.” IEEE TNSRE (2024). IEEE -
Chen, Xingjian,
Guo, Weiyu, Lin, Chuang, Jiang, Ning, Su, Jingyong. “Cross-subject lifelong learning for continuous estimation from surface electromyographic signal.” IEEE TNSRE (2024). IEEE -
Zhang, Gaomin,
Guo, Weiyu, Xiong, Xi, Guan, Zhongcheng. “A hybrid approach combining data envelopment analysis and recurrent neural network for predicting the efficiency of research institutions.” Expert Systems with Applications 238 (2024). Pergamon -
Qiao, Ziyue, Xiao, Meng,
Guo, Weiyu, Luo, Xiao, Xiong, Hui. “Information filtering and interpolating for semi-supervised graph domain adaptation.” Pattern Recognition 153 (2024). Pergamon -
Zhang, He, Sun, Ying,
Guo, Weiyu, Liu, Yafei, Lu, Haonan, Lin, Xiaodong, Xiong, Hui. “Interactive interior design recommendation via coarse-to-fine multimodal reinforcement learning.” ACM MM (2023) -
Lin, Chuang, Chen, Xingjian,
Guo, Weiyu, Jiang, Ning, Farina, Dario, Su, Jingyong. “A BERT based method for continuous estimation of cross-subject hand kinematics from surface electromyographic signals.” IEEE TNSRE 31 (2022). IEEE -
Ma, Chenfei,
Guo, Weiyu, Zhang, Hang, Samuel, Oluwarotimi Williams, Ji, Xiaopeng, Xu, Lisheng, Li, Guanglin. “A novel and efficient feature extraction method for deep learning based continuous estimation.” IEEE RA-L 6(4) (2021). IEEE -
Ma, Chenfei, Lin, Chuang, Samuel, Oluwarotimi Williams,
Guo, Weiyu, Zhang, Hang, Greenwald, Steve, Xu, Lisheng, Li, Guanglin. “A bi-directional LSTM network for estimating continuous upper limb movement from surface electromyography.” IEEE RA-L 6(4) (2021). IEEE -
Guo, Weiyu, Ma, Chenfei, Wang, Zheng, Zhang, Hang, Farina, Dario, Jiang, Ning, Lin, Chuang. “Long exposure convolutional memory network for accurate estimation of finger kinematics from surface electromyographic signals.” JNE 18(2) (2021). IOP Publishing -
Chen, Chao,
Guo, Weiyu, Ma, Chenfei, Yang, Yongkui, Wang, Zheng, Lin, Chuang. “sEMG-based continuous estimation of finger kinematics via large-scale temporal convolutional network.” Applied Sciences 11(10) (2021). MDPI -
Guo, Linlin, Zhang, Hang,
Guo, Weiyu, Fang, Jian, Lu, Bingxian, Ma, Chenfei, Li, Guanglin, Lin, Chuang, Wang, Lei. “Deep Learning for Device-free Human Activity Recognition Using WiFi Signals.” Generalization With Deep Learning (2021) -
Guo, Linlin, Zhang, Hang, Wang, Chao,
Guo, Weiyu, Diao, Guangqiang, Lu, Bingxian, Lin, Chuang, Wang, Lei. “Towards CSI-based diversity activity recognition via LSTM-CNN encoder-decoder neural network.” Neurocomputing 444 (2021). Elsevier -
Wang, Zheng, Wang, Zhuo, Liao, Jian, Chen, Chao, Yang, Yongkui, Dong, Bo, Chen, Weiguang, Chen, Wenxuan, Lei, Ming,
Guo, Weiyu. “CNN-DMA: a predictable and scalable direct memory access engine for convolutional neural network.” GLSVLSI (2021) -
Chen, Wenxuan, Wang, Zheng, Lei, Ming, Dong, Bo, Wang, Zhuo, Yang, Yongkui, Chen, Chao,
Guo, Weiyu, Liang, Chen, Zhang, Qian. “Improving system latency of AI accelerator with on-chip pipelined activation preprocessing and multi-mode batch inference.” IEEE AICAS (2021). IEEE -
Wang, Chao,
Guo, Weiyu, Zhang, Hang, Guo, Linlin, Huang, Changcheng, Lin, Chuang. “sEMG-based continuous estimation of grasp movements by long-short term memory network.” Biomedical Signal Processing and Control 59 (2020). Elsevier -
Guo, Weiyu, Wang, Chao, Lin, Chuang, Wang, Chenrui. “Long short term memory model based continuous estimation of human finger joint angles.” IEEE RCAR (2019). IEEE -
Zhang, Hang, Wang, Chao,
Guo, Weiyu, Guo, Linlin, Lin, Chuang. “DFNN-based gesture recognition with the shift and damage of the HD-sEMG electrodes.” IEEE ROBIO (2019). IEEE -
Chen, Rui, Chen, YuanZhi,
Guo, Weiyu, Chen, Chao, Wang, Zheng, Yang, Yongkui. “SEMG-based gesture recognition using GRU with strong robustness against forearm posture.” IEEE RCAR (2021). IEEE -
Ma, Chenfei,
Guo, Weiyu, Xu, Lisheng, Li, Guanglin. “Finger joint angle estimation based on sEMG signals and deep learning method.” IEEE RCAR (2021). IEEE
Further preprints
-
Wang, Shaoguang,
Guo, Weiyu, Fei, Ben, Shao, Xiaohong, Wang, Zhihui, Ouyang, Wanli. “Diagnosing and Narrowing the Simulation-to-Real Gap in Powder X-ray Diffraction with a Wet-Dry Agentic Loop.” arXiv preprint arXiv:2608.22400 (2026) Paper -
Wang, Shaoguang,
Guo, Weiyu, Dai, Rushi, Zhao, Yiren, Guo, Yandong, Xiong, Hui. “Suppression Sticks, Locality Is Fragile: A Closed-Loop Target-and-Control Audit of Task-Vector Negation in VLA Policies.” arXiv preprint arXiv:2608.04692 (2026) Paper -
Wang, Haobo, Sun, Baoli, Zou, Anqi, Huang, Dongsheng, Lv, Zelin, Wang, Ning, Li, Rui, Zhou, Dongzhan,
Guo, Weiyu, Wang, Zhihui, Ouyang, Wanli. “LabRobFail: A Benchmark for Robotic Failure Analysis in Chemical Self-driving Laboratory.” arXiv preprint arXiv:2607.23704 (2026) Paper -
Zhang, He, Sun, Ying, Chen, Ziyang, Luo, Qicheng, Zhao, Yiren,
Guo, Weiyu, Li, Pengteng, Guo, Yandong, Xiong, Hui. “Source-Lifted Flow Matching for Intervenable Multimodal Imitation.” arXiv:2607.10206v2 (2026). Paper -
Liu, Jiaxin, Xu, Xun, Zhang, Zhenhao, Wang, Hanqing, Chen, Ruiqi, Chang, Shi,
Guo, Weiyu, Kneip, Laurent. “Event-VLA: Action-Conditioned Event Fusion for Robust Vision-Language-Action Model.” arXiv preprint arXiv:2606.29384 (2026) Paper -
Chen, Ziyang, Wang, Shaoguang,
Guo, Weiyu, Cai, Qianyi, Zhang, He, Li, Pengteng, Zhao, Yiren, Guo, Yandong. “PHASER: Phase-Aware and Semantic Experience Replay for Vision-Language-Action Models.” arXiv preprint arXiv:2606.03598 (2026) Paper -
Wang, Shaoguang,
Guo, Weiyu, Chen, Ziyang, Hu, Xuming, Xiong, Hui. “Where to Focus: Query-Modulated Multimodal Keyframe Selection for Long Video Understanding.” arXiv preprint arXiv:2604.17422 (2026) Paper -
Deng, Han, Zou, Anqi, Zhang, Hanling, Fei, Ben, Zhang, Chengyu, Wang, Haobo, Guo, Xinru, Li, Zhenyu, Wang, Xuzhu, Yang, Peng, Zhang, Fujian,
Guo, Weiyu, Shao, Xiaohong, Liu, Zhaoyang, Tang, Shixiang, Wang, Zhihui, Ouyang, Wanli. “Owl-AuraID 1.0: An Intelligent System for Autonomous Scientific Instrumentation and Scientific Data Analysis.” arXiv preprint arXiv:2603.29828 (2026) Paper -
Xu, Yijie, Yao, Huizai, Guo, Zhiyu, Li, Pengteng, Liu, Aiwei, Hu, Xuming,
Guo, Weiyu, Xiong, Hui. “You Only Need 4 Extra Tokens: Synergistic Test-Time Adaptation for LLMs.” arXiv preprint arXiv:2510.10223 (2025) Paper
Selected patents
- Training method, training device of continuous motion information prediction model PCT/CN2020/133443
- Intelligent interactive glove with AI chip, interactive method and storage medium PCT/CN2021/107108
- Power efficiency test method, adjustment method, computer equipment CN202010389035.4
- An in-memory computing accelerator and its optimization method CN202011406904.6
- An automatic optimization method of graph data processing framework CN202011358762.0
Experience
I received my Ph.D. in Artificial Intelligence from HKUST (Guangzhou) in 2026, supervised by Prof. Hui Xiong (AAAS / IEEE / AAAI / ACM Fellow, Founding Editor-in-Chief of Nature npj AI).
Education
- 2026.08 - Present,
 The Chinese University of Hong Kong, Multimedia Laboratory (MMLab), Postdoctoral Fellow
- 2022.08 - 2026.07,
 The Hong Kong University of Science and Technology (Guangzhou), Artificial Intelligence, Ph.D.
- 2019.08 - 2022.06,
 University of Chinese Academy of Sciences, School of Artificial Intelligence, M.S.
- 2015.09 - 2019.06,
 Dalian University of Technology, School of Software Engineering, B.S.
Collaboration & industry
Principal Investigator (PI), XLab · Embodied Foundation Models & Frontier Research
AI² Robotics (智平方)
Leading XLab’s embodied foundation model development and frontier embodied AI research, connecting brain-inspired architectures, Vision-Language-Action models, and real-world robotic systems.
Postdoctoral Fellow
MMLab, The Chinese University of Hong Kong · 2026 - Present
Brain-inspired embodied intelligence and Vision-Language-Action models.
Research Associate
Johns Hopkins University · 2021.09 - 2022.06
Supervised by Prof. Alan Yuille (IEEE Fellow). Published at ECCV.
Long-term Collaboration
Imperial College London · 2019 - Present
With Prof. Dario Farina. Published papers in JNE, THMS.
Selected milestones
- Published 50+ international papers at top venues (ICML, NeurIPS, CVPR, ECCV, ICLR, AAAI, IJCV, JNE, THMS, TMM, RA-L), with 800+ citations (h-index 15).
- Applied for 16 patents, including 2 PCT international patents.
- Co-founded StarVLA: open-source VLA framework with 3.5K+ GitHub stars (460+ forks), adopted by Unitree and Alibaba Qwen, ranked Top 10 Most Influential Embodied AI Repositories 2025.
- Principal Investigator (PI), XLab, leading embodied foundation models and frontier embodied AI research at AI² Robotics (智平方, valuation exceeding 10 billion RMB).
- Involved in writing one book chapter (Generalization with Deep Learning) on World Scientific book.
- Reported by People’s Daily (人民日报), China Central Television (央视新闻), and Guangzhou Daily.
- Co-founded a neural-interface company with a valuation of over 70 million RMB.
Teaching & community
Teaching & mentorship
Invited talks & teaching:
Brain-inspired embodied intelligence & embodied AI for science
Research talk · Cong Lab, Stanford University
Embodied AI course Upcoming
Invited teaching · Turing Class, Peking University
XLab Students I Mentor:
Junjie Ke柯俊杰
Tsinghua University
Yihan Liu刘一含
Tsinghua University
Yujie Zhu祝宇杰
Tsinghua University
Yiwen Liang梁伊雯
Tsinghua University
Qilin Wang王麒麟
Peking University
Zhuoxi Zeng曾卓西
Peking University
Jiarui Ye叶家睿
Peking University
Kairan Ding丁凯然
Peking University
Jiahang Li李佳航
Peking University
Zhirui Zhang张郅睿
Peking University
Yunkai Tang汤云开
Peking University
Weiqi Chen陈伟琪
Peking University
Tianyi Xu徐天艺
Peking University
Pengteng Li李鹏腾
HKUST (Guangzhou)
Shaoguang Wang王韶光
HKUST (Guangzhou)
Yiren Zhao赵毅人
HKUST (Guangzhou)
Ziyang Chen陈梓扬
HKUST (Guangzhou)
Ziyang Rao饶子扬
HKUST (Guangzhou)
Zicheng Liu刘子铖
The University of Hong Kong
Siyu Chen陈思羽
Institute of Automation, CAS
Junyu Long龙君昱
Harbin Institute of Technology (Shenzhen)
Chenyang Jiang蒋晨阳
Harbin Institute of Technology (Shenzhen)
Guoying Sun孙国英
Harbin Institute of Technology (Shenzhen)
Jianyu Chen陈建宇
Harbin Institute of Technology (Shenzhen)
Mengfan Kong孔梦帆
Harbin Institute of Technology (Shenzhen)
Yanjun Li李宴军
Huazhong University of Science and Technology
Zishang Xiang项子尚
Beijing Institute of Technology
Yishuo Cheng程一硕
Shandong University
Han Yan严晗
Beijing University of Posts and Telecommunications
Academic service
Conference Reviewer: AAAI, NeurIPS, CVPR, ICLR, ICML
Journal Reviewer: Scientific Reports, IEEE Robotics and Automation Letters (RA-L)
Invited Speaker: Shenzhen Loop Area Institute: “Brain-Inspired Computing and Embodied Intelligence”
Awards
- National Scholarship for Postgraduates, 2021
- The President Scholarship of CAS, 2021
- Merit Student of UCAS, 2020
- Outstanding Graduates of DUT (top 1%), 2019
- Outstanding Graduates of Liaoning Province (top 1%), 2019
- Merit Student of DUT, 2018
Let’s connect.
I welcome conversations about embodied AI, brain-inspired computing, and academic collaboration.